|
Jiyang Lee I'm a Ph.D. candidate at Seoul National University, where I work on robot learning with Prof. Seong-Woo Kim (Civil and Environmental Engineering). From January to July 2026, I was an international visiting graduate student at the University of Waterloo with Prof. Roya Firoozi, and our collaboration continues. I received my Master's degree and Bachelor's degree in Mechanical Engineering from Sogang University in 2017 and 2015, respectively. Previously, I worked as a research engineer at LG Display (2020-2024), and as a robotics researcher at KIST (2018-2020). |
|
ResearchMy research focuses on making generative robot policies reliable in closed-loop interaction with real robots. Before my Ph.D., I spent several years building vision and robotic systems for production lines and field robots, where they were judged by whether they kept working after deployment rather than by an offline score. That experience shapes how I study vision-language-action models and diffusion policies: I run them on real robots to understand why policies that look strong offline still fail once they act in the physical world. I am now extending the same perspective to humanoids, starting with the data and simulation infrastructure needed to test whether world-action-model predictions translate into executable behavior. |
|
Under Review
|
Blind review
Jiyang Lee, Roya Firoozi, Seong-Woo Kim Submitted to IEEE International Conference on Robotics and Automation (ICRA), 2027 |
|
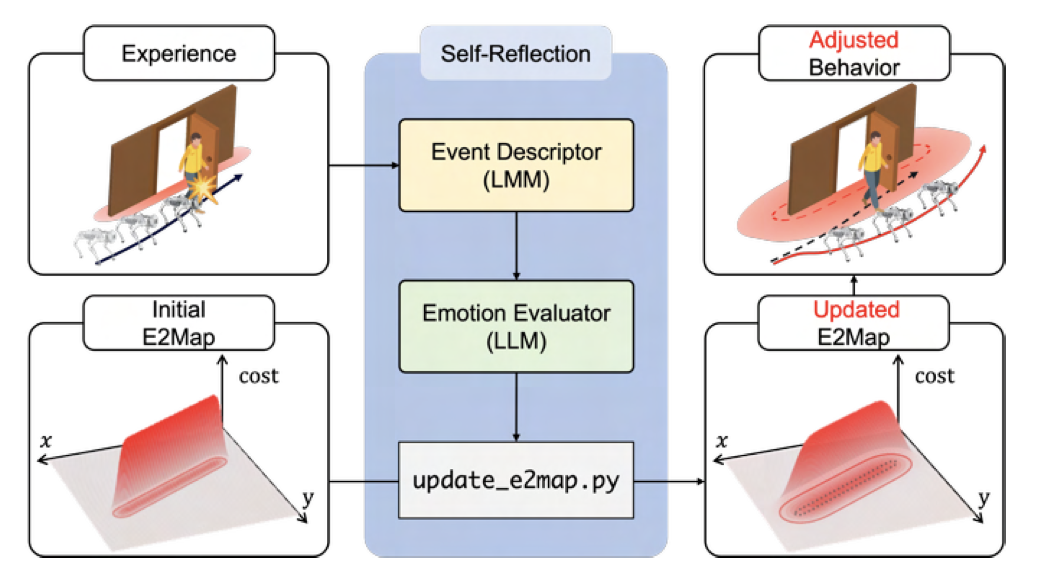
E2Map: Experience-and-Emotion Map for Self-Reflective Robot Navigation with Language Models
Chan Kim, Keonwoo Kim, Mintaek Oh, Hanbi Baek, Jiyang Lee, Donghwi Jung, Soojin Woo, Younkyung Woo, John Tucker, Roya Firoozi, Seung-Woo Seo, Mac Schwager, Seong-Woo Kim IEEE ICRA, Atlanta, USA, May 2025 [PDF] / [link] |
|
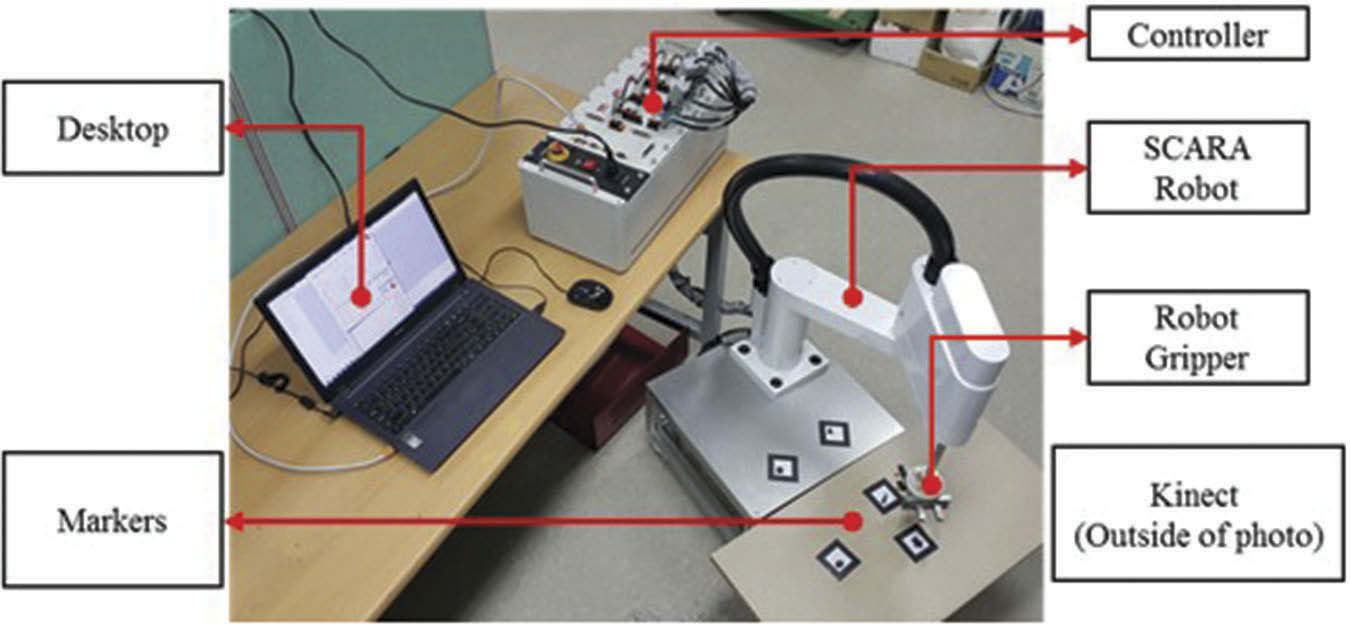
Path planning for SCARA robot based on marker detection using feature extraction and labelling
Jiyang Lee, Cheol-soo Lee International Journal of Computer Integrated Manufacturing, 31(8), 769-776, 2018 [PDF] / [link] |
|
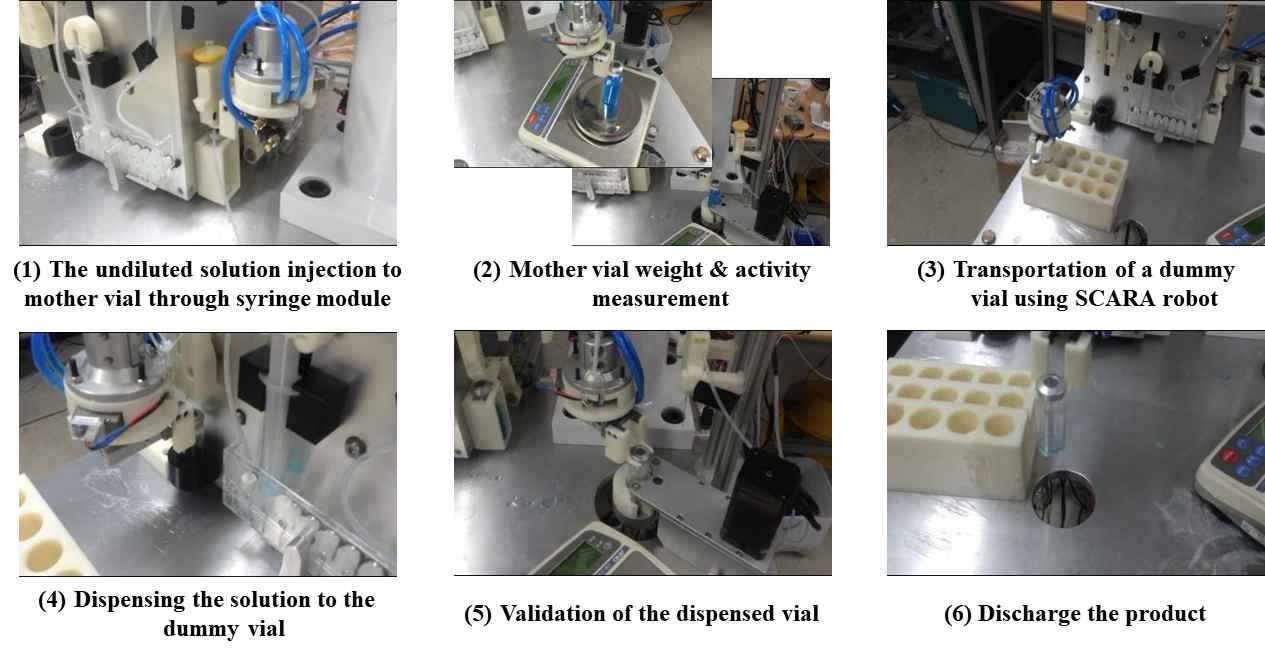
Development of Robotic Dispensing System for Radiopharmaceuticals using SCARA Robot
Jiyang Lee, Cheol-soo Lee, Dong-gu Lee Journal of the Korean Society of Manufacturing Technology Engineers, 26(5), 441-449, 2017 [Best Paper Award] [PDF] / [link] |
|
Website template inspired by Jon Barron |